Simorgh V1
Simorgh V1 is here
The first version of the Simorgh robot is now implemented and running! This version is static; just a ball that gives connectivity and sensing on battery.
This is a testbed for developing the first functionalities of the Simorgh system:
- Connectivity extension in hard-to-reach and low coverage scenarios.
- Sensing integrated into the connectivity service.
- Centralized control panel.
- OTA updates (for my own mental health!)
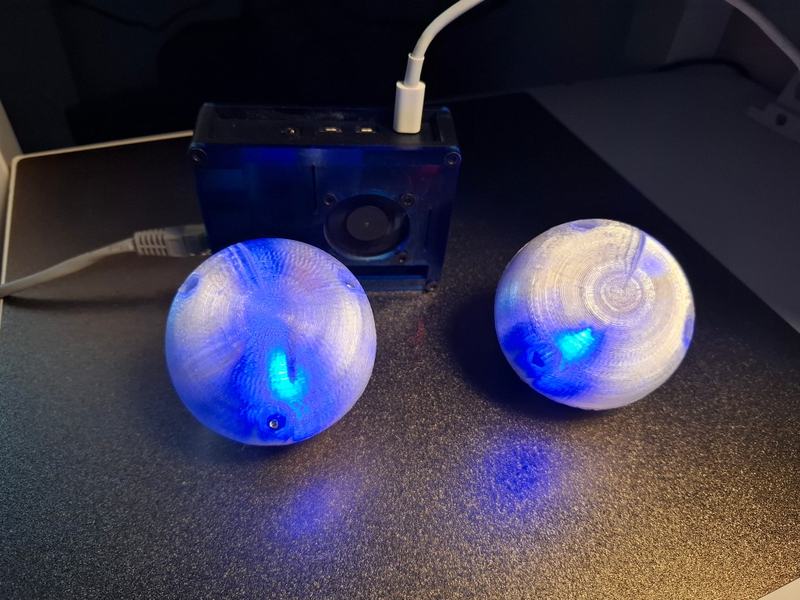
Here is a picture of two of the five nodes I have built so far, along with the control center hardware.